Robotics · Control · Reinforcement Learning

Building motion
that thinks.

PhD researcher working on motion planning, control, and learning for robots that operate in the real world.

Scroll
01

About

I’m Lei Shi — a robotics researcher building robust algorithms that fully exploit a robot’s dynamics and sensing to act in natural, unstructured environments.

Research interests: robot motion planning & control, reinforcement learning, and unmanned ground vehicles.

One day, I want to make a difference in our daily life with my knowledge as a passionate researcher. Even a little difference is the fantastic realization of my life's ultimate meaning.

02

Experience

Education

  • Sept. 2016 ~ Jun. 2020

    Undergraduate

    Shandong University

    Explored vehicle engine major.

  • Jan. 2021 ~ Dec. 2022

    Master Student

    Johns Hopkins University

    Explored robotics major, especially on motion planning and control.

  • Sept. 2023 ~ May 2025

    PhD Student

    University of Wisconsin-Madison

Research

  • May. 2021 ~ Sept. 2022

    Research Intern

    Tencent CO.LTD, Robotics-X Lab

    Robot Dexterous Manipulation

  • May. 2022 ~ Dec. 2022

    Research Assistant

    Johns Hopkins University, Laboratory for Computational Sensing and Robotics

    Rough Terrain vehicle Learning-based Control

  • May. 2023 ~ Aug. 2023

    Research Intern

    Tencent CO.LTD, Robotics-X Lab

    Robot Dexterous Manipulation

  • Sept. 2023 ~ May. 2025

    Research Assistant

    University of Wisconsin - Madison

    Autonomous Vehicles

  • Nov. 2025 ~ Present

    Research Intern

    Futian Lab, Tencent & International Digital Economy Academy (IDEA)

    Robot Dexterous Manipulation

Teaching

  • Sept. 2022 ~ Dec. 2022

    Teaching Assistant

    Johns Hopkins University

    Introduction to Linear Systems and Theory

  • Aug. 2023 ~ Dec. 2023

    Teaching Assistant

    University of Wisconsin - Madison

    Dynamics

  • Jan. 2024 ~ May. 2024

    Teaching Assistant

    University of Wisconsin - Madison

    Dynamics

  • Jan. 2025 ~ May. 2025

    Teaching Assistant

    University of Wisconsin - Madison

    Statics

03

Selected Work

02

Dexterous Manipulation Online Planning

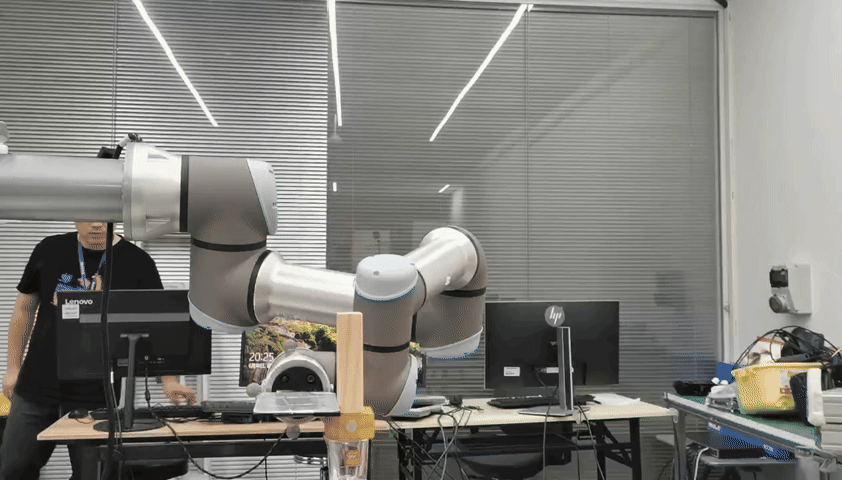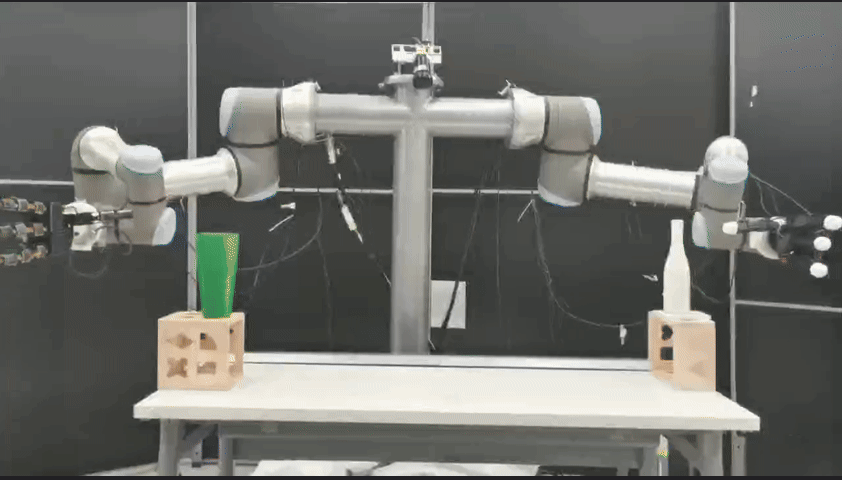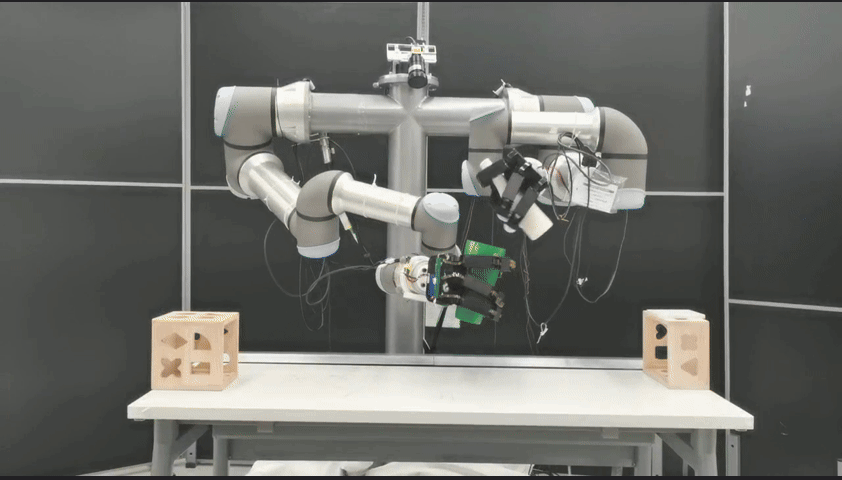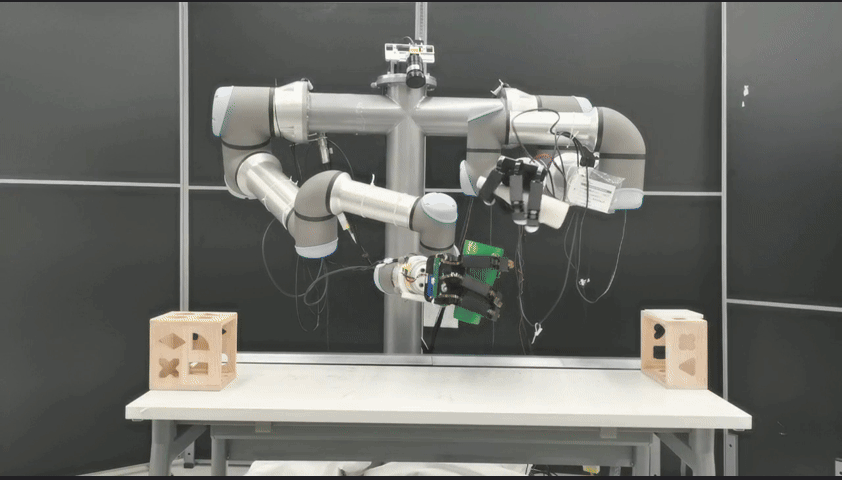
  • Comprehensive and robust manipulation of objects.
  • Fast enough to support online computation and replanning.
  • A foundation for manipulation replanning and recovery.
03

Human-Like Motion Planning Algorithm

  • Analyzed human motion and its underlying mechanism — coordinated movement and compliant movement.
  • Implemented coordinated movement for 2-D translation and rotation.
  • Developed a parametric optimal-control algorithm for the problem.
04

Rough-Terrain Ground Vehicle Control

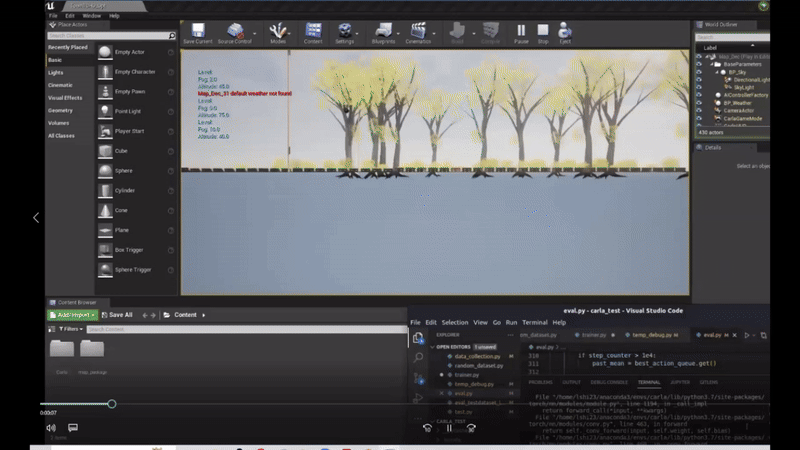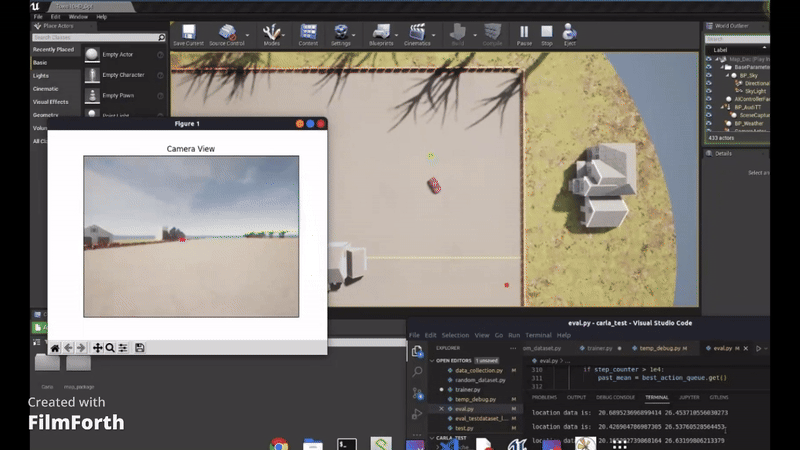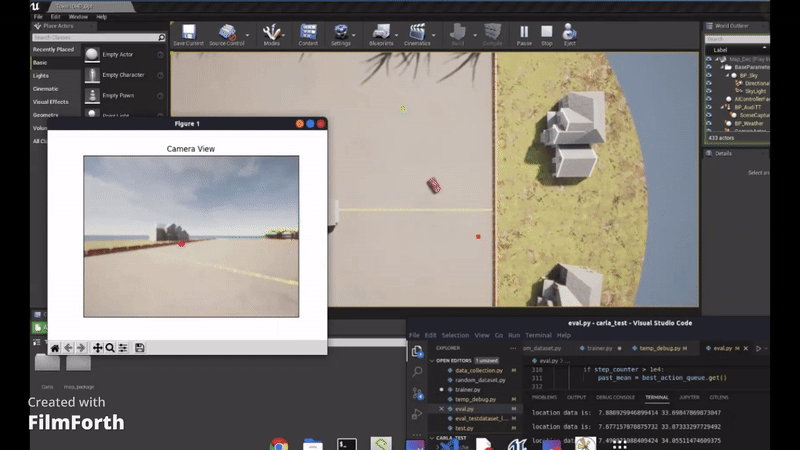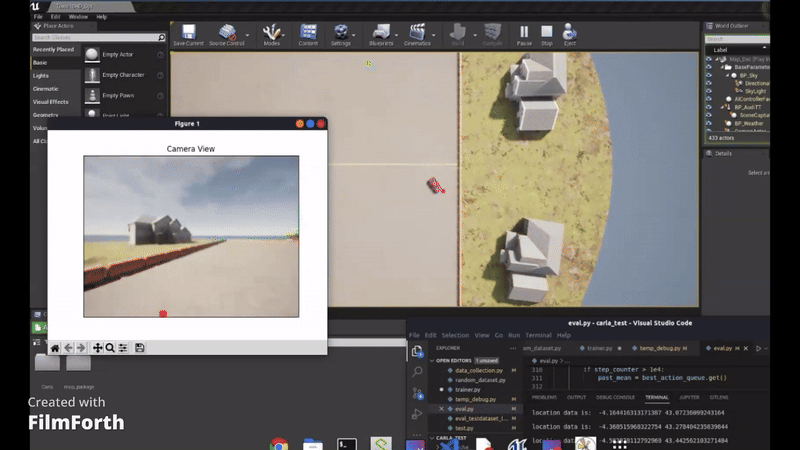
  • Built a time-aligned dataset from scratch in CARLA — collecting, transforming and plotting sensor data in real time.
  • Implemented a CNN + LSTM model to predict vehicle motion in urban and arbitrary rough-terrain areas (maps authored in RoadRunner).
  • Used an MPPI-control algorithm to guide motion planning and control.
05

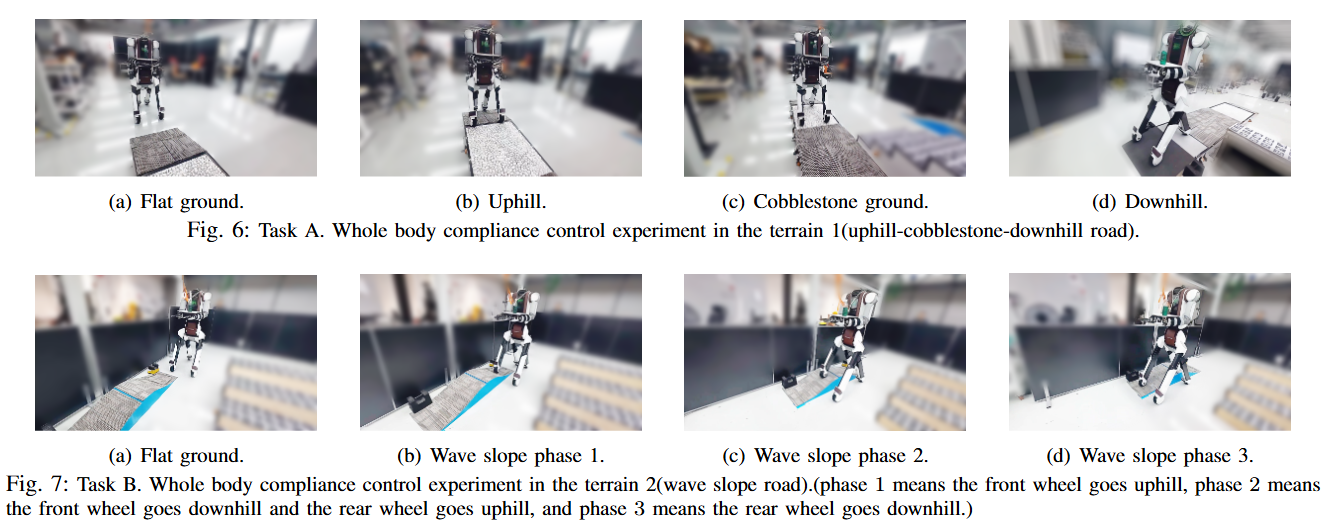
Optimal Control of the Upper Body in Humanoid Robots

  • Derived an analytical bang-bang control solution using variable-damping impedance control to cut lower-limb energy cost from upper-body oscillation, while keeping passively-held objects stable under uncertain lower-limb motion.
06

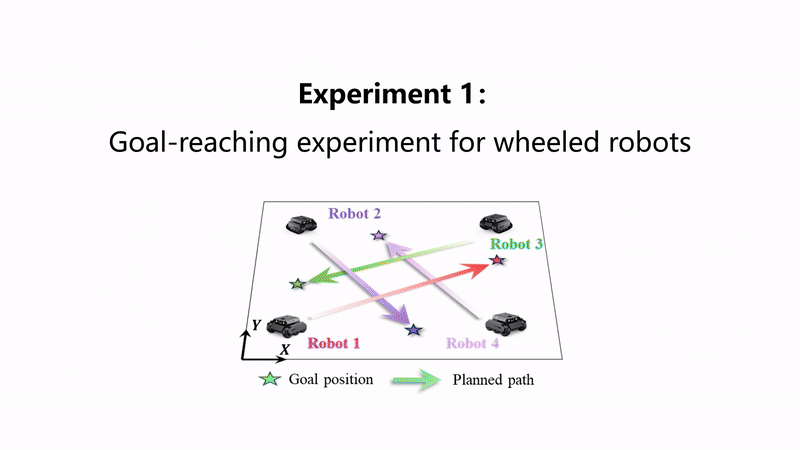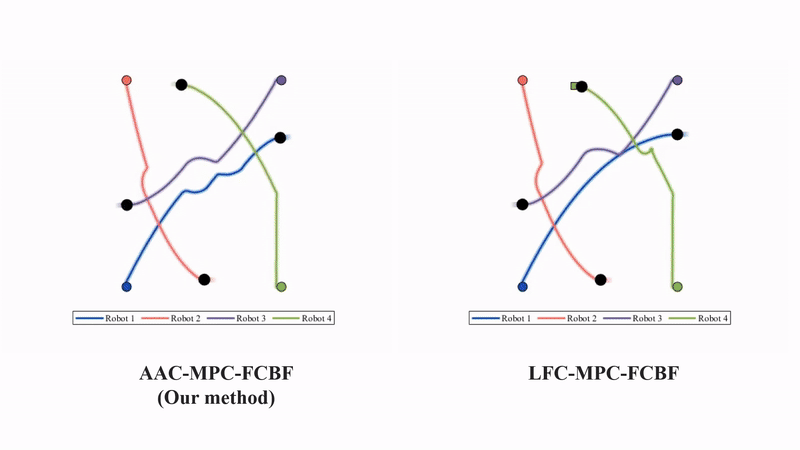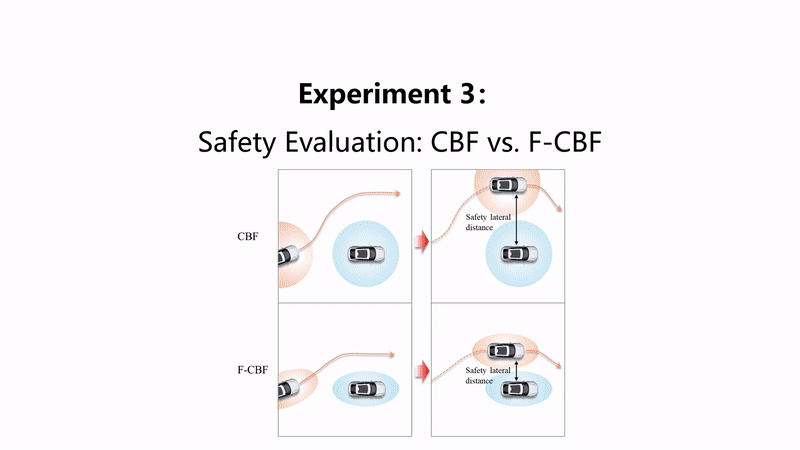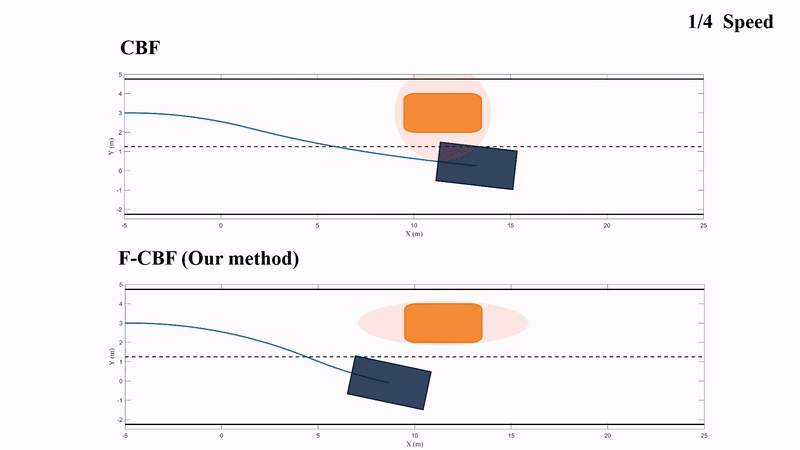
Fairness-Oriented Control for Safety-Critical Multi-Robot Systems

  • Introduced an Alternative Authority Control (AAC) framework for dynamic distribution of control authority among agents.
  • Proposed a Model Predictive Control with Flexible Control Barrier Functions (MPC-FCBF) for stronger dynamic obstacle avoidance.
  • Combined AAC and MPC-FCBF into a hierarchical architecture for efficient authority allocation and obstacle avoidance.
04

Writing

All writing →